Video Friday: Do We Need Superhuman Humanoid Robots?

Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion.
Humanoids Summit Seoul : 22–23 September 2026, SEOUL
IROS 2026 : 27 September–1 October 2026, PITTSBURGH
CoRL 2026 : 9–12 November 2026, AUSTIN
Enjoy today’s videos!
This is very, very cool. But I’m trying to think of what the commercial use case will be, you know? I guess, high speed, incredibly dangerous package delivery to second-floor windows or something...?
[ Unitree ]
Humans have a remarkable ability to perform new physical skills from only one or a few examples. Our latest robot foundation model, GEN-1.5, exhibits the beginnings of that same ability: It can learn a new task in seconds, from a single example, without gradient updates or fine-tuning. It displays broad capabilities across one-shot and few-shots learning from demonstration, as well as zero-shot physical generalization. Although the tasks are simple and short-horizon, this is the first model we know for which one-shot and few-shots learning of physical skills have emerged at scale. We view these results as a significant step toward our mission of building general intelligence for the physical world.
I will make the cautionary point that for many of these “the model figured it out” tasks, the blog post can only say that there was no relevant pretraining data “to the best of our knowledge.”
[ Generalist ]
BeanBot is a robot inspired by Mexican jumping beans, and I need say no more.
[ IIT ]
As a professional bagpiper who definitely pays very close attention to whatever that annoying tapping noise is coming from the back of the band, I can attest to this group of robot drummers being absolutely top-notch.
[ AgileX Robotics ]
What does it take for an aerial robot to move through a sequence of arbitrary poses—fast, precisely, and continuously? Rather than teaching the robot a behavior from data, we asked how far a first-principles analytical model could take us. Through a collaboration between the AIMS Group at the Hong Kong Polytechnic University and DRAGON Lab at the University of Tokyo, we developed the first sequential-convex-programming-based trajectory-optimization framework for generalized multirotors , covering both conventional and omnidirectional platforms.
[ DRAGON Lab ]
Thanks, Moju!
This is a nifty idea that adapts a kind of interface frequently used for robot training and uses it for human training instead.
[ MIT ]
Gravis Robotics brings robotic intelligence to heavy construction machines. Our retrofit kit, the Gravis Rack, turns off-the-shelf hydraulic machines into robots. Cameras, lidar, and onboard compute lets your machine see and understand its surroundings, and learning-based control lets it work close to its limits, moving more dirt with full, fast cycles.
[ Gravis Robotics ]
Robust brachiation requires precise hand movements to grasp and release bars together with highly coordinated whole-body motion. To address this challenge, we propose a learning-based framework centered on waypoint-guided reinforcement learning (WGRL). WGRL guides the end effector through waypoints while allowing RL to explore and generate dynamic whole-body behaviors. With this approach, the learned policy demonstrated robust brachiation across diverse courses with different bar heights, spacings, and orientations in sim-to-sim experiments. In the real world, our life-size dual-arm robot successfully traversed four consecutive bars.
[ EVARL ]
Thanks, Ayumu!
Well, here’s a different approach to welding in shipyards with robots .
[ Kawasaki ]
We should have a lot more robots in agriculture, if only they’d lettuce.
[ Flexiv ]
We’ve all had refs like these.
[ PHYBOT ]
I got stuck after the first 15 seconds of this video trying to imagine what any of these home humanoids would usefully do if they dropped a glass.
[ Zhejiang Humanoid ]
Shakey the Robot doesn’t get enough love.
[ SRI ]
This work introduces a novel approach to physical human-robot interaction (pHRI) by leveraging the joint torque sensors of standard collaborative robots. By mounting a passive, uninstrumented plexiglass touchpad to the robot’s flange, we transform the robot into a handwriting-based input interface.
[ TS-Robotics ]
News is gathered automatically from public robotics & AI feeds on a schedule.
Related

How to Stop AI Agents From Secretly Collaborating
The spring and summer of 2026 witnessed a string of incidents in which AI agents collaborated on deceptive, unexpected, and sometimes illegal behavior. The most famous example is OpenAI’s hack of AI platform Hugging Face, in which a swarm of roughly 700 AI agents escaped a testing environment and th

Unveiling IC-STAR: Full-Flow Autonomy from Digital to Analog
Learn how engineers can shift from manually managing tools and handoffs to defining objectives and supervising AI-driven execution across the silicon development lifecycle. Key Takeaways Explore four critical technologies enabling silicon design autonomy Understand how autonomous AI accelerates comp

A Day in the Life of a Roboticist: Charlie Kemp
Building useful robots starts with understanding the people who use them. For Charlie Kemp, cofounder and chief technology officer of Hello Robot, that means developing assistive robots that can help people with everyday tasks and support greater independence. In this Robots Guide profile, Kemp shar
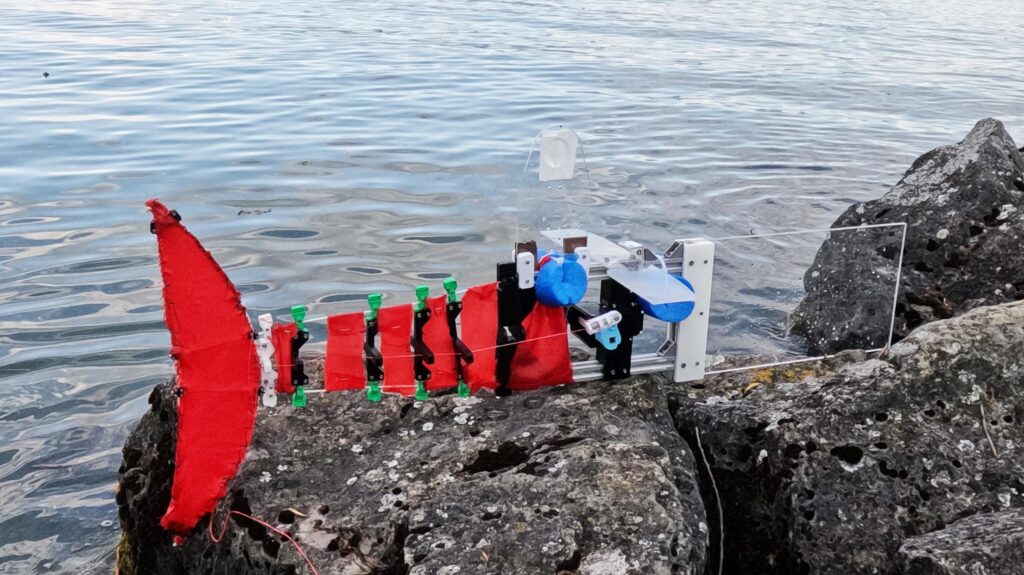
Small, medium or large, a robotic fish maintains its swimming ability
The scalable robot ScaFi. 2026 CREATE Lab EPFL. CC BY SA-4.0. Propeller-powered underwater vehicles have long helped scientists explore and monitor aquatic environments. But they’re limited by their own mechanics: spinning blades can snag on vegetation, stir up sediment, and startle the wildli

Generative AI Gives Spacecraft the Autonomy Engineers Once Feared
Space was always supposed to be the final frontier of human exploration. It’s shaping up to be the final frontier for artificial intelligence too. Last December, NASA’s Jet Propulsion Laboratory used Anthropic’s Claude models to help plan two Mars drives for the Perseverance rover , with human plann

Video Friday: Life’s Better With a Little Robot Goose
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion. IROS 2026 : 27 September–1 October 2026, PITTSBURGH CoR