What does it take for a robot to hold a conversation with a room, not just a person?
By Umar Farooq
That was one of the questions at the heart of my last week (20th-24th July) at the Imperial Robotics Summer School, hosted at Imperial College, London; a week that sharpened my thinking and pushed me to look at robotics problems from angles I don’t usually get to in my day-to-day work.
The summer school brought together emerging researchers, academics, and industry professionals from across the robotics community for an intensive, hands-on programme. I came away having learned a huge amount, from expert-led lectures on robot kinematics, dynamics, sensing and control, and robot learning, through to specialised sessions on aerial robotics, robot intelligence, surgical robot vision, bio-inspired sensing and control, and personal assistive robotics.
One of the standout parts of the week was getting into Imperial’s robotics labs themselves, seeing research up close across adaptive and intelligent robotics, aerial robotics, robotic surgery, manipulation and touch, and assistive robotics. Alongside researchers from across the UK and beyond, we dug into real-world robotics challenges spanning quadruped locomotion, vision-based robot learning, tactile sensing, and healthcare applications.
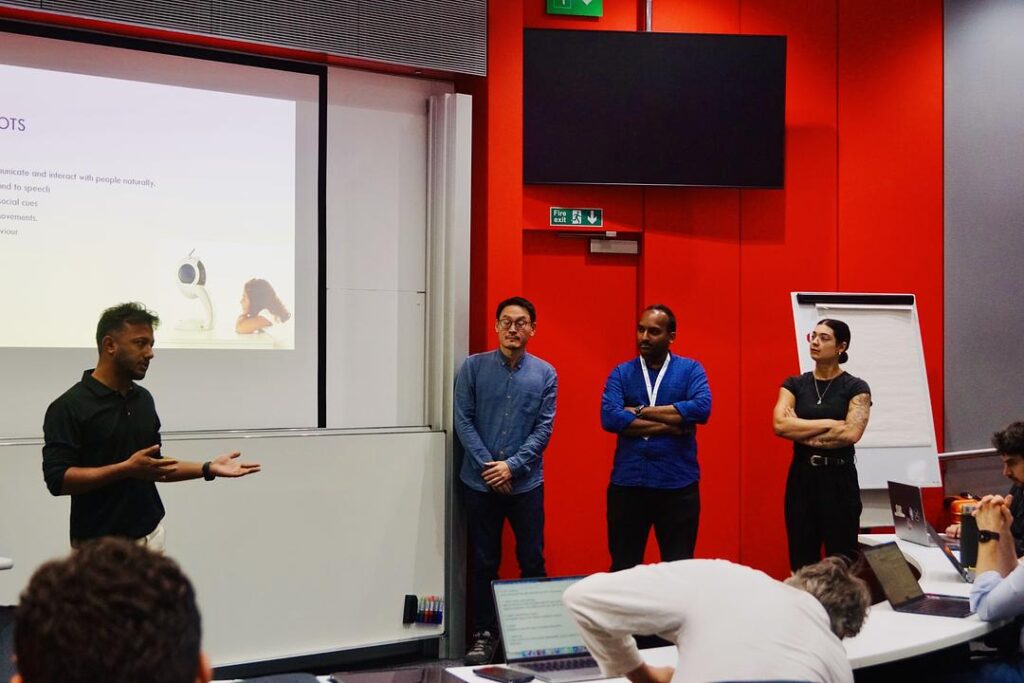
Our group project focused on enabling a robot to interact with several people at once, rather than the typical one-to-one interaction most social robots are designed around. We worked on detecting the active speaker in real time, tracking each person’s identity through the interaction, and generating natural gaze and head-turn behaviour so the robot felt genuinely attentive to the whole group rather than just one person. Along the way, I got a much clearer picture of the full pipeline from language to motion, how an LLM translates natural intent into structured commands, how those get mapped to high-level robot functions, how inverse kinematics turns that into joint trajectories, and how it all finally reaches the actuators through the robot’s control stack. It was a great, hands-on introduction to just how hard multi-party human-robot interaction really is. and I came away with a much deeper appreciation for the interdisciplinary side of robotics research.
None of this would have been possible without UK RAS STEPS, who funded my place as one of five RTPs selected to attend. Beyond this summer school, UK RAS STEPS has been really helpful for my development, with different workshops along the way that I’ve learned a lot from. A special thank you also to Marie Daniels for her support and guidance throughout the application process.
Thanks as well to the wider Imperial College, London team, the lecturers, researchers, and fellow participants, for a week full of great conversations and a real learning environment.
News is gathered automatically from public robotics & AI feeds on a schedule.
Related
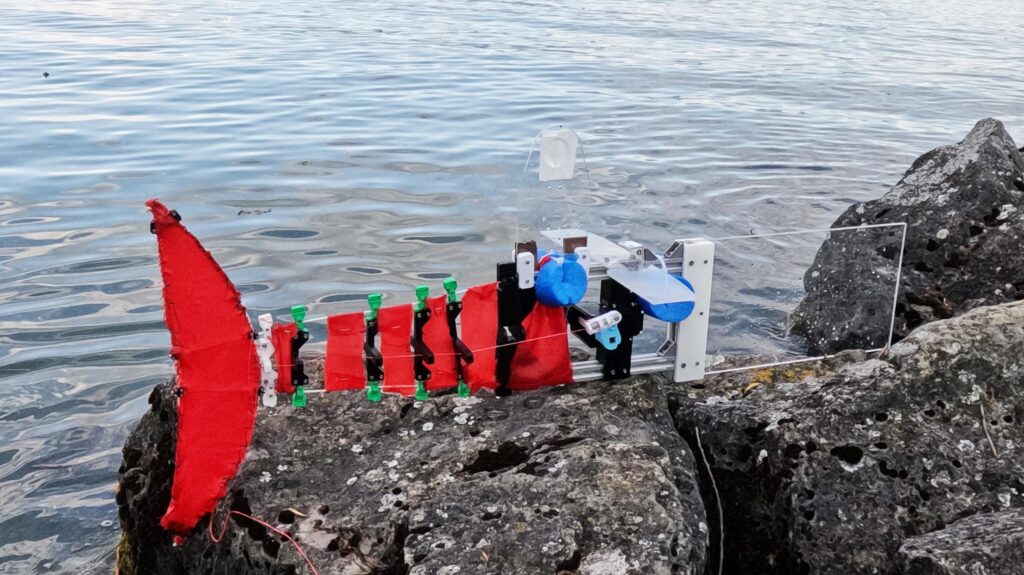
Small, medium or large, a robotic fish maintains its swimming ability
The scalable robot ScaFi. 2026 CREATE Lab EPFL. CC BY SA-4.0. Propeller-powered underwater vehicles have long helped scientists explore and monitor aquatic environments. But they’re limited by their own mechanics: spinning blades can snag on vegetation, stir up sediment, and startle the wildli

Video Friday: Life’s Better With a Little Robot Goose
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion. IROS 2026 : 27 September–1 October 2026, PITTSBURGH CoR
Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger
Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently. Aaron Edsinger is CEO and Co-Founder of Hello Robot, a robotics company dedicated to developing practical, safe, and accessible robots for people. With a pa
An open source approach to physical AI from Intrinsic
Deborah Lupton / Pop Chips / Licenced by CC-BY 4.0 Intrinsic (an AI robotics group at Google) announced that the company is making parts of its platform open source. Intrinsic Core™ is a set of ROS-compatible capabilities for building sophisticated robotic applications. The capabilities included in

Mexican EPICS in IEEE Team Builds Portable Educational Platform
In Guadalajara, Mexico, many high schools have motivated teachers and talented students with an interest in science, technology, engineering, and mathematics, but they lack access to advanced tools such as robotics laboratories. The resources shortfall limits the students’ opportunities for hands-on
What’s coming up at #IROS2026?
The 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026) will be held from 27 September – 1 October in Pittsburgh, USA. The programme includes plenary and keynote talks, workshops, tutorials, forums, competitions, and a debate. Keynote talks The keynote talks wi