Entangled robotic matter with cohesive motion
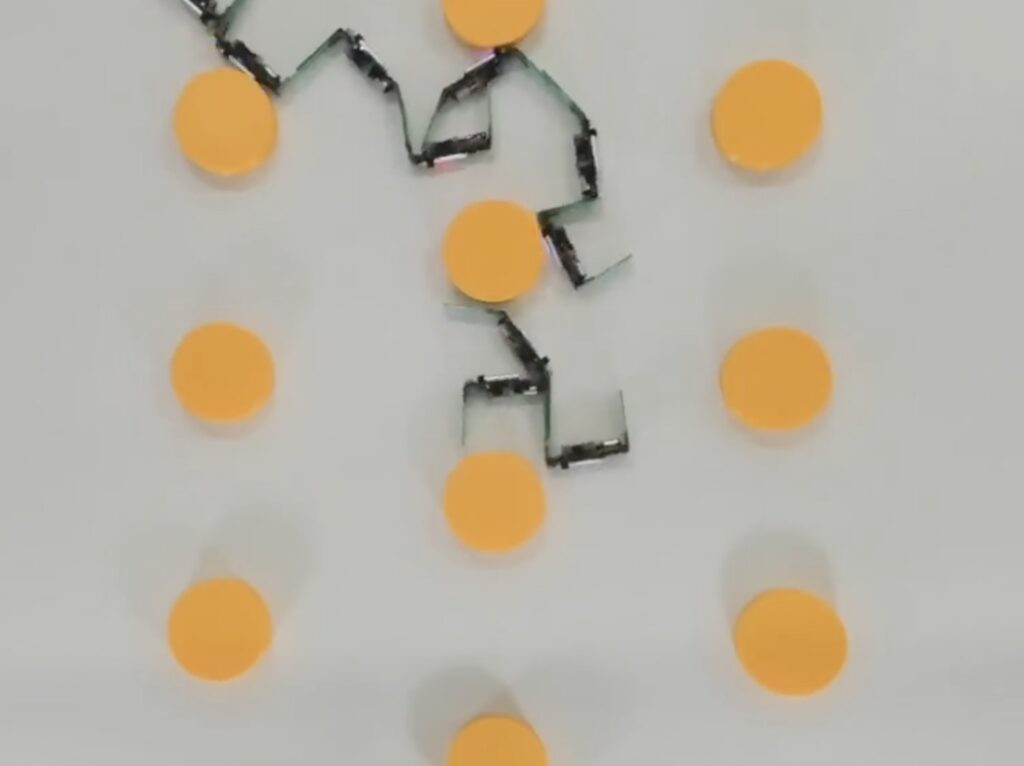
By Syl Kacapyr
Cornell engineers have developed a robotic collective that behaves less like a machine and more like a material that flows, reshapes and adapts to its environment without centralized control.
The system, called the Cross-Link Collective, consists of dozens of small robots that have limited mobility individually, but together exhibit coordinated and sustained motion. The research, published May 20 in Science Robotics , demonstrates a robotic system that resembles soft matter, continuously deforming and reorganizing as it moves, driven by what researchers call mechanical intelligence.
“Instead of relying on explicit computation and communication, the system shifts the intelligence into the shape of the robots and their physical interactions,” said corresponding author Kirstin Petersen, associate professor of electrical and computer engineering and the Aref and Manon Lahham Faculty Fellow in the Cornell Duffield College of Engineering. “We’re leveraging the contact dynamics to let useful behaviors emerge, so the system naturally settles into configurations that reduce internal stresses and improve motion.”
Each robotic module measures about 200 millimeters in length and 20 millimeters in width, and contains a small motor that drives it to oscillate between two shapes, an “I” and a “U.” These oscillations generate forces against the ground, allowing the modules to inch forward and jostle into one another. At each end of the module are weak Velcro patches, enabling them to temporarily latch and unlatch onto neighboring modules.
On their own, the modules move slowly and inefficiently. But when they entangle into chains, they begin to move collectively, self-organizing into shifting configurations that prove resilient in challenging environments.
https://robohub.org/wp-content/uploads/2026/06/WithControl_Rep1_100X-HD_1080-WEB-H264_4000.mp4
On incline surfaces, chains of robotic modules moved more reliably than individuals, which often stalled depending on their orientation. In obstacle fields, the collective behaved like a flowing material in which connections formed to maintain cohesion, then broke apart to prevent jamming.
“It doesn’t matter if one module has a compromised battery or fails for other reasons,” said lead author Danna Ma, visiting lecturer in electrical and computer engineering. “The system stays functional because it can adapt. It is redundant and doesn’t depend on any single module.”
Despite the minimal approach, the researchers showed that even a small amount of computation can improve system properties. To enhance cohesion, isolated modules emit an audible distress signal, prompting nearby modules to slow down and allow the straggler to reconnect.
“There is no centralized sensing or control,” Ma said. “Each module can infer when it has lost contact with the group by how much it’s being jostled and then use an audible buzz to slow down nearby modules while it catches up. It’s as simple as that.”
Co-authors at the Georgia Institute of Technology developed the original design of the module, which Petersen and Ma refined over years of experimentation and statistical analysis to improve its ability to entangle and operate in large numbers. That process revealed how even subtle changes in module size and other characteristics can influence how effectively they connect and move as a group.
The Cross-Link Collective draws inspiration from active gels – materials whose molecular links continually form and dissolve while maintaining overall structure. The findings could help inspire new forms of soft-matter engineering, though the researchers mostly see the system as a tool for studying how mechanical intelligence can give rise to resilient emergent behaviors in robot collectives.
“It’s helpful for us to start thinking about what we can encode into the physics of a system itself, as robots are increasingly applied to real-world scenarios that are highly unreliable and dynamic,” Petersen said. “Counterintuitively, by giving up exact control over configurations and coordination, we gain a surprising range of useful behaviors.”
News is gathered automatically from public robotics & AI feeds on a schedule.
Related
Small, medium or large, a robotic fish maintains its swimming ability
The scalable robot ScaFi. 2026 CREATE Lab EPFL. CC BY SA-4.0. Propeller-powered underwater vehicles have long helped scientists explore and monitor aquatic environments. But they’re limited by their own mechanics: spinning blades can snag on vegetation, stir up sediment, and startle the wildli

Video Friday: Life’s Better With a Little Robot Goose
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion. IROS 2026 : 27 September–1 October 2026, PITTSBURGH CoR
Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger
Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently. Aaron Edsinger is CEO and Co-Founder of Hello Robot, a robotics company dedicated to developing practical, safe, and accessible robots for people. With a pa
An open source approach to physical AI from Intrinsic
Deborah Lupton / Pop Chips / Licenced by CC-BY 4.0 Intrinsic (an AI robotics group at Google) announced that the company is making parts of its platform open source. Intrinsic Core™ is a set of ROS-compatible capabilities for building sophisticated robotic applications. The capabilities included in

Mexican EPICS in IEEE Team Builds Portable Educational Platform
In Guadalajara, Mexico, many high schools have motivated teachers and talented students with an interest in science, technology, engineering, and mathematics, but they lack access to advanced tools such as robotics laboratories. The resources shortfall limits the students’ opportunities for hands-on
What’s coming up at #IROS2026?
The 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026) will be held from 27 September – 1 October in Pittsburgh, USA. The programme includes plenary and keynote talks, workshops, tutorials, forums, competitions, and a debate. Keynote talks The keynote talks wi