A flapping robot swims and flies like a diving bird
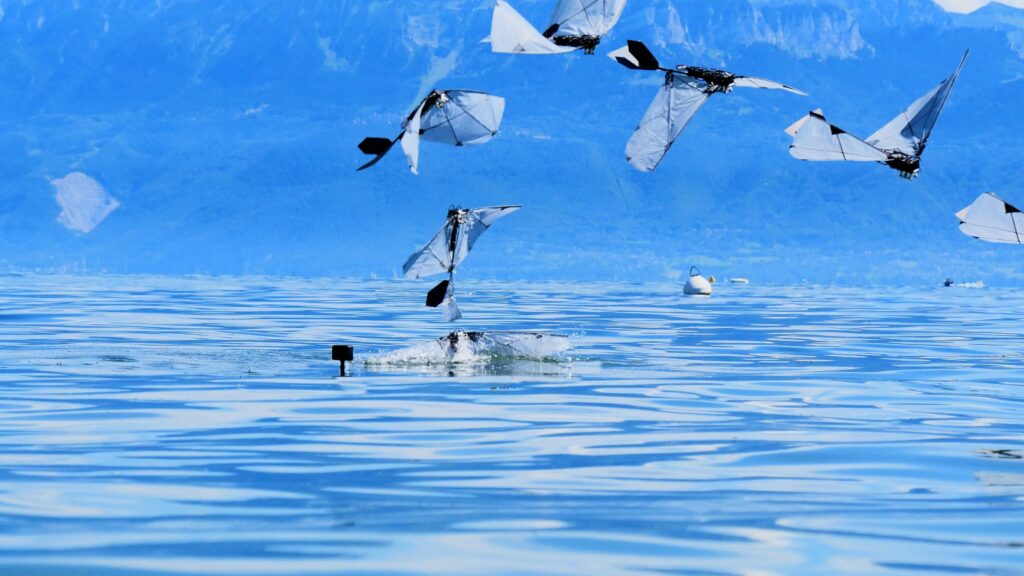
Image copyright: Raphael Zufferey .
By Jennifer Chu
Loons, gulls, puffins, and petrels are some of the 100 species of birds that can both fly and swim. These diving birds can plunge in water to swim after prey, and then leap back into the air to fly away. Now, inspired by these naturally aquatic aviators, engineers at EPFL and MIT have designed a robot that can swim underwater, and flap out of the water to continue flying through air, much like diving birds.
The “flapping-wing aerial-aquatic vehicle,” or FAAV, weighs less than 300 grams and is designed to help scientists study the mechanics that enable diving birds to fly through air and water. The robot has a central body, or fuselage, two flexible, flapping wings, and a steerable tail. The wings and tail can be swapped out for different sizes. In experiments carried out in a water tank and a lake, the engineers identified combinations of wing size, flapping frequency, and tail angle that enable the robot to smoothly transition from swimming through water, to breaking through the surface, to flying through the air.
Their results, published in Science , can help scientists understand how diving birds adapt their flight mechanics to move through air and water, which have very different physical properties. The design could also launch a new class of aerial-aquatic drones and vehicles. The researchers envision such winged robots could be deployed to fly to and sample from aquatic regions that would otherwise be too dangerous for traditional ocean vessels to access.
Image copyright: Raphael Zufferey .
“Our dream vision is for oceanographers, marine biologists and coastal communities to launch this robot from a boat, or from shore, and it would fly close to the area of interest, such as an iceberg, a port facility or over a pod of whales,” says lead author and former EPFL researcher Raphael Zufferey, now an assistant professor of mechanical engineering at MIT. “It would dive into the water to take a measurement or collect a sample, and fly back to deliver the data at a fraction of the cost of traditional methods. Then it could go back out to dive for more.”
Flight mechanics
Zufferey began working on the robot as a postdoctoral fellow in the Laboratory of Intelligent Systems ( LIS ) and Biorobotics Lab ( BioRob ) in EPFL’s School of Engineering, under the supervision of respective lab heads and co-authors Dario Floreano and Auke Ijspeert. He completed the work at MIT, where he now leads the AURA Lab , which focuses on engineering bioinspired aerial and aquatic vehicles. The study also includes co-authors from Northwest Indian College (USA).
With bird biomechanics in mind, the team developed a robot with wings made of thin membranes coated with hydrophobic nanoparticles to help wick away water. The body contains a battery and a waterproof electric motor that drives a crankshaft, which in turn pumps the wings up and down at pre-set frequencies. The tail is motorized, enabling it to change its angle to help the robot fly up or dive down.
The researchers performed experiments first in a small water tank at EPFL, and then in Lake Geneva. They found that wing size (80 centimeters) and flexibility are key; the wings need to be flexible enough to minimize flapping amplitude in water, and firm enough to keep the robot aloft in the air. The robot could swim at speeds of almost one meter per second when it flapped with a frequency of around 5 hertz (five flaps per second), and fly at around 6 meters per second when flapping at a similar frequency. These speeds and flapping frequencies are similar to those of actual diving birds. To make the leap from water to air, the robot must be pitched at a relatively steep 70 degrees to keep its wingtips from touching the water’s surface.
Image copyright: Raphael Zufferey .
Like a bird, but without feet
Interestingly, this combination of wing size, flap frequency, and tail pitch enabled the robot to swim underwater, launch off the surface, and fly without something that many diving birds require: feet. “If you look at birds, most birds need to paddle their feet at the surface to take off. And the question was, do we need the same for robots? And it turns out we don’t,” Zufferey says. “No one’s been able to fly out of the water with wings.”
Going forward, the team is improving the design of the wings to enable them to turn in addition to flapping up and down. They will also test the robot’s performance under turbulent conditions, such as swimming out of choppy waters, and flying through wind. Then, they hope to deploy the vehicle to help answer questions in ocean science.
Reference
Leaping out of the water: Aerial-aquatic locomotion with flapping wings , Raphael Zufferey, Simon L. Jeger, Moritz Hüsser, Fernando Ruiz, Anthony Lapsansky, Auke Ijspeert, Dario Floreano , Science (2026).
News is gathered automatically from public robotics & AI feeds on a schedule.
Related
Small, medium or large, a robotic fish maintains its swimming ability
The scalable robot ScaFi. 2026 CREATE Lab EPFL. CC BY SA-4.0. Propeller-powered underwater vehicles have long helped scientists explore and monitor aquatic environments. But they’re limited by their own mechanics: spinning blades can snag on vegetation, stir up sediment, and startle the wildli

Video Friday: Life’s Better With a Little Robot Goose
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion. IROS 2026 : 27 September–1 October 2026, PITTSBURGH CoR
Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger
Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently. Aaron Edsinger is CEO and Co-Founder of Hello Robot, a robotics company dedicated to developing practical, safe, and accessible robots for people. With a pa
An open source approach to physical AI from Intrinsic
Deborah Lupton / Pop Chips / Licenced by CC-BY 4.0 Intrinsic (an AI robotics group at Google) announced that the company is making parts of its platform open source. Intrinsic Core™ is a set of ROS-compatible capabilities for building sophisticated robotic applications. The capabilities included in

Mexican EPICS in IEEE Team Builds Portable Educational Platform
In Guadalajara, Mexico, many high schools have motivated teachers and talented students with an interest in science, technology, engineering, and mathematics, but they lack access to advanced tools such as robotics laboratories. The resources shortfall limits the students’ opportunities for hands-on
What’s coming up at #IROS2026?
The 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026) will be held from 27 September – 1 October in Pittsburgh, USA. The programme includes plenary and keynote talks, workshops, tutorials, forums, competitions, and a debate. Keynote talks The keynote talks wi