Pegasus 1.6 brings video understanding to physical AI, says TwelveLabs
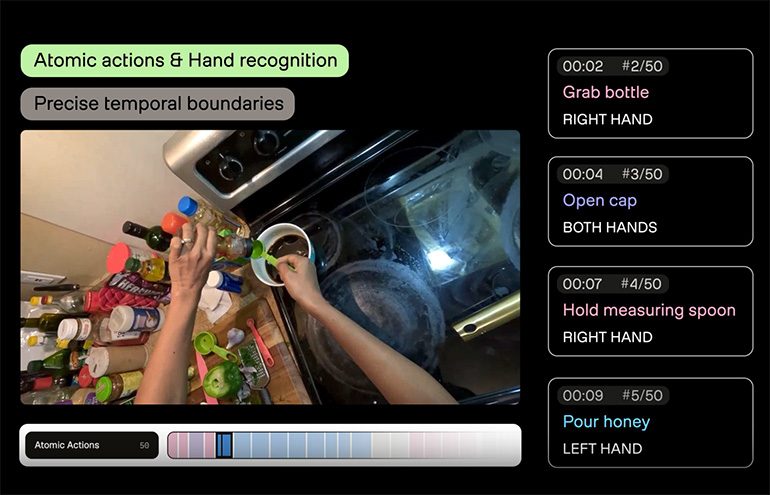
Pegasus provides temporal context, spatial reasoning, and judgement on whether a task was completed. Source: TwelveLabs
As the physical world rapidly digitalizes, AI teams are gathering vast amounts of complex video, but transforming raw footage into actionable models remains a critical challenge, according to TwelveLabs Inc. The company today released its Pegasus 1.6 model with added capabilities for understanding and navigating complex real-world environments.
“Our mission has always been to help machines understand how the world works through video,” stated Jae Lee, co-founder and CEO of TwelveLabs. “Physical AI is the next expression of that mission. Most of what people know about doing physical work, such as a changing grip or a recovery after something slips, has never been captured in a form a machine can learn from.”
“With our newest model release, we can now turn that footage into structured, reviewable knowledge, so robotics and physical AI teams can train on real human experience instead of starting from scratch,” he added.
Founded in 2021, TwelveLabs said it has created a “full-stack video intelligence platform” using its Marengo and Pegasus models, which it designed to see and understand video the way humans do in a fraction of the time. Developers can use this single system that gets smarter over time to access and act on all of their video content, said the Seoul-based company .
Pegasus 1.6 focuses on egocentric video
TwelveLabs said its latest version of Pegasus marks its expansion into physical AI , generating rich insights from real-world perspectives. It solves workflow-specific challenges so that machines such as robots, drones, and autonomous vehicles can perceive, reason, and safely act in the physical world like never before, the company claimed.
“We’re focused on the video understanding layer,” Jae Lee told The Robot Report . “You can’t just take millions of hours of video and feed it into a robotics model and expect useful training data to come out. You first need to understand what’s happening in the video, what action is taking place, when it happens, what the person is interacting with, how the behavior changes over time, and when other people or bystanders appear in the field of view.”
“Pegasus 1.6 provides that more precise understanding so robotics and data teams can then turn it into the training data they need,” he added.
TwelveLabs noted that Pegasus 1.6 is its first AI model built to understand egocentric video , which is shot from the point of view of the person doing the work. This could be someone cooking a meal, assembling parts on a factory line, or operating a robot remotely. The model does not require specific cameras, said Lee.
“We’re not requiring robotics teams to use a particular camera or proprietary hardware to capture that footage,” he said. “What matters is being able to capture the actions and interactions taking place from the operator’s point of view.”
In addition, Pegasus 1.6 can work with existing video data and allows for analysis of still images in addition to video.
“One of the reasons we’re focused on egocentric video is that it’s much easier to collect and scale than teleoperation data,” acknowledged Lee. “The goal is to take that footage and make it more useful for robotics teams by identifying the actions taking place, breaking them into precise time segments and capturing finer-grained details about the behavior.”
Head-mounted footage can break models trained on broadcast, instructional, and cinematic video. Source: TwelveLabs
TwelveLabs supports five workflows
Pegasus 1.6 currently supports five workflows powered by its video-native model. They include:
Action segmentation and labeling: This feature accelerates model training with standardized datasets by automatically generating precise, time-stamped action labels for tasks, steps, objects, and hand-object interactions from raw video, mapped to the customer’s domain-specific taxonomy.
Dense caption labeling: This enables natural language understanding for robots by producing rich, descriptive language for spatial relationships, scene context, and hand-object interactions to train advanced language-conditioned robot policies.
Quality scoring: Users can save time by filtering out low-quality video by automatically evaluating and scoring video clips for action clarity, framing, and stability before sending footage to human reviewers.
Search and curation: Customers can uncover critical edge cases by surfacing rare events, long-tail scenarios, and duplicate clips across an entire video repository using simple, natural-language search queries.
Consent and compliance flagging: Privacy and compliance can be maintained by detecting and flagging faces, bystanders, and sensitive onscreen or paper data before video footage enters downstream development pipelines.
Editor’s note: Physical AI is among the session track topics at RoboBusiness 2026, which will be on Oct. 20 and 21 in Santa Clara, Calif. Register now to attend.
Register now and help us celebrate 20 years of RoboBusiness!
Customers to benefit from existing capabilities
Pegasus 1.6 builds on the video understanding capabilities that TwelveLabs developed for enterprises that maintain massive video libraries.
The new release extends Pegasus 1.5’s functionality that attracted several new customers. TwelveLabs cited Time-Based Metadata (TBM), which allows users to define a custom schema and automatically receive timestamped, structured metadata from video content. This is particularly useful in aiding contextual understanding, as people often narrate what they are doing in egocentric clips, it said.
Pegasus 1.6 has also improved entity recognition for more consistent tracking of hands, objects, and tools across clips. The model also offers faster, more cost-efficient processing for high-volume video workloads, according to TwelveLabs.
Lee said that TwelveLabs’ system adds video understanding to other…
Les actualités sont collectées automatiquement depuis des flux publics robotique & IA.
Articles liés
SafeWorld emerges from stealth to build, deploy robot safety simulation technologies
SafeWorld’s platform provides testing and simulation software to help enterprises evaluate and deploy robots safely and responsibly. The post SafeWorld emerges from stealth to build, deploy robot safety simulation technologies appeared first on The Robot Report .
Jabil discusses the pace of humanoid robot development and production
Jabil, which is working with robot developers such as Apptronik, provides a design perspective on humanoid progress. The post Jabil discusses the pace of humanoid robot development and production appeared first on The Robot Report .
Helm.ai reaches $70M in signed commercial contracts for its foundation models
Helm.ai trained its foundation models using its unsupervised 'deep teaching' methodology to master the structure of the physical world itself. The post Helm.ai reaches $70M in signed commercial contracts for its foundation models appeared first on The Robot Report .
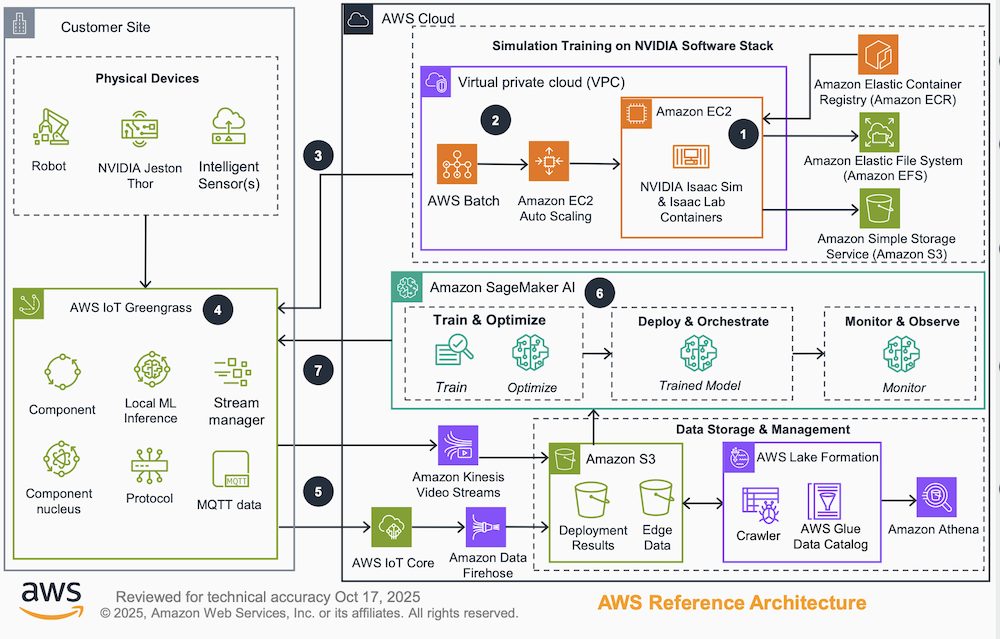
AWS launches open-source Physical AI Toolchain for robotics
The toolchain combines AWS and NVIDIA tools for synthetic data generation, model training, simulation and validation, edge deployment, and continuous improvement. The post AWS launches open-source Physical AI Toolchain for robotics appeared first on The Robot Report .
PTC acquisition positions Schneider Electric to challenge Siemens
The Schneider Electric acquisition of PTC gives it a 'digital thread' from design through operations, but it needs to integrate data and software, says Interact Analysis. The post PTC acquisition positions Schneider Electric to challenge Siemens appeared first on The Robot Report .
Teradyne Robotics, Elite Robots settle cobot dispute
Teradyne Robotics and Elite Robots have settled their software dispute, ending the legal case without disclosing the terms of the agreement. The post Teradyne Robotics, Elite Robots settle cobot dispute appeared first on The Robot Report .