Video Friday: Albatross Falls, Spins, Self-Rights, and Sails Away
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion.
CoRL 2026 : 9–12 November 2026, AUSTIN
Humanoids 2026 : 6–9 December 2026, SANTA CLARA, CA
Enjoy today’s videos!
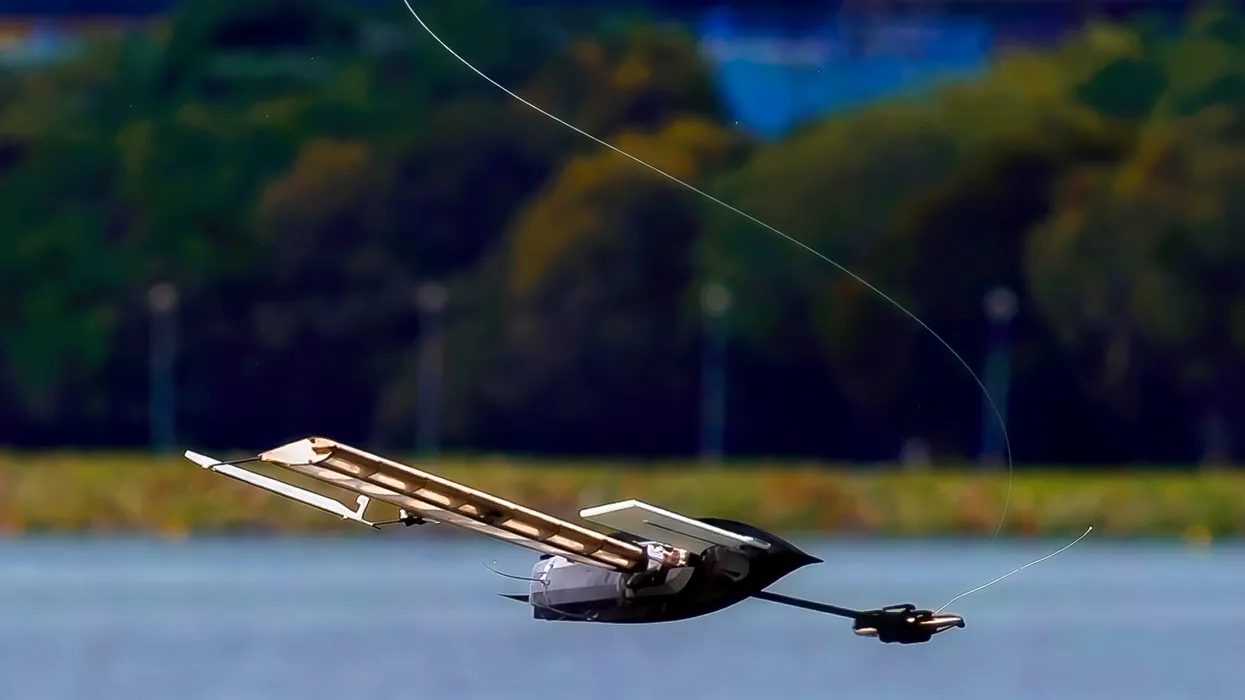
We’ve developed ALBATROSS (Airborne Lander with Buoyant AuToROtating Sailing Sensor), a hybrid aerial-marine robot. It can be released from the air, autorotate down to the water without a parachute, passively self-right after landing, and then reuse the same rigid wings as sails for autonomous wind-powered navigation. The key idea is to make the physical structures do as much of the work as possible. Rather than carrying separate systems for aerial descent, landing, and marine propulsion, ALBATROSS uses the same wings for both autorotation and sailing, with minimal actuation. Ultimately, we’re interested in whether platforms like this could combine rapid aerial deployment with persistent, energy-efficient marine sensing.
[ Singapore University of Technology and Design ] paper via [ Science Robotics ]
Thanks, Shane!
I’m just getting so burnt out on the humanoid publicity stunts , you know?
[ Figure ]
Sharpa unveiled three major proprietary new products at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS): D01, the first integrated tactile-sensing robot built for dexterous manipulation; W02, a next-generation fully tactile, ultracompact, lightweight dexterous hand; and AE01, a high-fidelity haptic exoskeleton data glove.
[ Sharpa ]
Why will Boston Dynamics win the humanoid robotics race? We’ve already commercialized autonomous mobile robots, creating markets with Spot and Stretch. Now we’re doing it again with Atlas: learning in real environments, designing for manufacturing at scale, and introducing a new era of physical intelligence.
[ Boston Dynamics ]
This work presents a lightweight, compliant footpad that enhances the terrain adaptability of a hopping robot. The design combines a planar foot supported by a compliant spherical joint for self‑alignment with embedded spines to improve traction on uneven or slippery surfaces.
[ CLIMB Lab, University of Toronto ]
Heterogeneous robot teams distribute complementary capabilities across specialized agents, but their physical roles and capacities typically remain fixed throughout a mission. We present HARP, a Heterogeneous Aerial Robotic modules Platform, in which independently deployable aerial robots physically reconfigure to compose their capabilities for field operations.
[ General Robotics Lab ]
Some very impressive mobility from ANYmal .
[ ETH Zurich RSL ]
Daniel writes, “I’m a high school student in Canada, and I built a self-constructing robot arm that assembles itself. It’s designed to be low-cost, with disaster response in mind: Small robots can squeeze through gaps in rubble but are too weak to move things, while big arms are strong but can’t fit through. My arm is split into three wheeled modules that travel separately, then dock together using a spring-lock mechanism.”
[ Daniel Zhu ]
Autonomous highway driving not impressive enough for you? Try this.
[ XPENG ]
The IT Imperial team has connected MaleCNS—a published connectome of a male fruit fly (Drosophila melanogaster)—to a physical Unitree G1 humanoid robot. The system creates a closed loop: camera → fruit-fly neural model → motor decoding → physical robot movement. The robot receives visual input through its stereo camera. The images are transformed into a representation adapted to the fly’s visual system, processed by the computational model based on the reconstructed nervous system, and then converted into movement commands for the robot.
[ IT Imperial ]
Thanks, Anna!
My guess is that this is far easier than it looks or far harder than it looks, and I’m honestly not sure which.
[ Paper ]
I cannot believe that this is still a thing, but good on them!
[ Tevel ]
In Part 1 of Dexterity Explained, we break down what manual dexterity is, why it matters, and how robotic hands and physical AI work together to bring greater skill, precision, and control to physical tasks.
[ Sanctuary AI ]
XPENG has a lot of money to build a lot of these robots. They do look very human. I’m not sure what they’re going to do, though.
[ XPENG ]
That’s a lot of robots! Tell me what they’re all going to do!
[ UBTECH ]
When floods swept away roads and bridges in Nepal, local drone pilots stepped in to help map the damage, support search teams, and deliver essential supplies to communities cut off from help. In this episode of Ground Truth with Flying Labs, host Leka Tingitana speaks with Uttam Pudasaini, an advisor to Nepal Flying Labs, and Raj Bikram Maharjan, cofounder of Airlift Technology, about the drone community’s response to the devastating floods of 26 August 2026.
[ WeRobotics ]
News is gathered automatically from public robotics & AI feeds on a schedule.
Related
The U.S. Nuclear Plant Fleet Is Leaning Into AI
If there is any place that would be off-limits to AI, the control room of a nuclear power plant certainly sounds like one. The nuclear industry is historically cautious and risk averse—understandable given the possible catastrophic consequences of an accident or a mistake. Even well-trained managers
This Disembodied Hand Is All the Robot You Need
A hand attached to the end of an arm is a given for most humans, but what if robots didn’t have to play by the same rules as we do? Researchers from ETH Zurich have turned an off-the-shelf robotic hand into a completely self-contained robot that walks on its fingertips while using those same fingers
HiPHI: A Large-Scale Benchmark for High-Precision Human Motion and Object Interaction
This White Paper gives robotics researchers and engineers an overview of a new large-scale motion capture dataset built to close the data gap limiting humanoid robot learning. It also shows how policies trained on the dataset transfer to a real humanoid robot. What you will learn about: Why humanoid
What three days building a robot taught me
Last month, I went to York to build a robot. I came back with a robot, a tiny trophy-shaped sense of achievement, and somehow a few new friends. From 25th-27th August, I joined the UK RAS STEPS MicroMaze Robot Hackathon at the Institute for Safe Autonomy, University of York. The brief sounded simple
6 Guidelines for Governing AI
For the first 10 years of my career, I worked in product management and data analytics by myself. I wrote database queries that pulled numbers out of corporate systems, built statistical models to predict what customers would buy, and shipped data pipelines that moved information between business sy
Attempts to Keep Humans in the AI Loop May Actually Push Them Out
A crucial safeguard against AI agents going rogue —keeping humans in the loop to review and approve their decisions—will fail unless designers and users change their current practices, a trio of leading AI ethics researchers argue. Though most autonomous agents have systems to keep users in the loop