Video Friday: Spot Plays to Show Its Whole-Body Manipulation
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion.
CoRL 2026 : 9–12 November 2026, AUSTIN
Humanoids 2026 : 6–9 December 2026, SANTA CLARA, CA
Enjoy today’s videos!
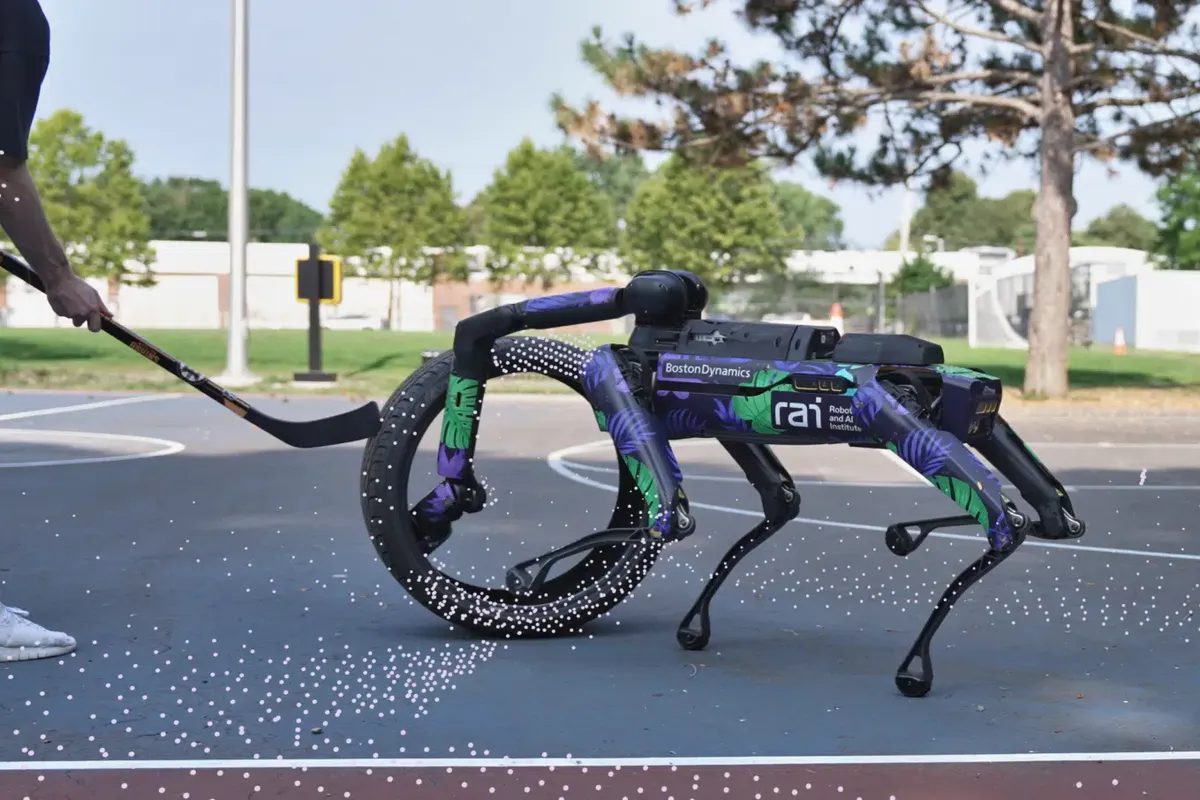
Some top-notch whole-body manipulation here from RAI, although it’s a little hard to tell whether there’s direct torso involvement, which is something that humans do with heavy or awkward stuff all the time.
“Anything that shows up as a blob in a depth image can be taken for the tire, whether a person walking past or a stray object on the floor. In a few runs the robot left the tire and went after something else.” That “something else” seems suspiciously vague, doesn’t it?
[ Robotics and AI Institute ]
We present a contact-centric learning framework for versatile humanoid mobility in complex and unstructured environments. Our approach bridges motion imitation and reinforcement learning by leveraging human motion data as a training prior while enabling autonomous adaptation to previously unseen terrains.
[ ETH Zurich Robotic Systems Lab ]
You’ve literally heard me say it a thousand times: The only things that could possibly make Reachy Mini better would be some wheels and a whole bunch of fancy hats.
But of course the only way I could possibly recommend the wheels is if Reachy Mini can totally wreck Microduck in a race.
[ Pollen Robotics ]
Luxonis is launching OAK 4 FFC, a 70 x 53 mm vision computer that lets humanoid and drone builders put up to five cameras wherever the robot needs them. The board runs sync, stereo depth, and AI itself, and calibrates from the scene instead of a checkerboard.
[ Luxonis ]
Thanks, Carson!
Coming soon: Mini Pupper 4!
[ MangDang ]
HX Friends explores different robotic hand designs powered by DYNAMIXEL, ranging from a single articulated finger and a gripper to three-, four-, and five-finger hands. The video includes motion demonstrations across the lineup and VR teleoperation of the multifinger hands.
[ Robotis ]
Thanks, Hyunwoo!
Developed by bluZenit, monkeyBot 2.0 is an innovative robotic platform designed to navigate complex industrial piping systems. Inspired by nature, monkeyBot 2.0 uses a unique gripping and climbing mechanism to move along vertical and horizontal pipes, navigate bends, and access challenging locations within industrial facilities.
[ bluZenit ]
Thanks, Trevor!
I understand that you need some kind of repeatable baseline or whatever for training robots to do stuff, but I would be so much more impressed with any cleaning robot at all if it would clean stuff that was actually dirty for once.
[ Generalist ]
Calling this a “robot” hand at this point might be a little bit premature, but this is the kind of technology we’re going to need for deployable robots that are compliant and safe.
[ BruBotics Human Robotics Research Center ]
Robotiq really is the OG of industrial manipulation, aren’t they?
And they’ve got a new tactile sensing gripper, too.
[ Robotiq ]
Introducing ANYmal X, which is the least likely to explode quadruped currently available for purchase.
[ ANYbotics ]
For those of us who prefer to play tennis alone.
[ LimX Dynamics ]
At Yulong River Scenic Area in Guangxi, China, DEEPRobotics’ Lite3 quadruped robot and LYNX M20 wheeled-legged robot are working together across a range of real-world tourism scenarios.
[ DEEPRobotics ]
In April 2025, the MAVLab team from TU Delft competed in the A2RL Drone Racing Championship in Abu Dhabi. Their AI algorithm MonoRace won the AI Grand Challenge and then beat three human FPV world champions. The drone uses only a single onboard camera and an IMU for state estimation. An onboard neural network maps the estimated state directly to motor commands.
[ MonoRace via Science Robotics ]
This video from Starship is worth watching mostly for the b-roll of their early prototypes.
[ Starship ]
Meet SAWbot, a bio-inspired amphibious robot that swims using a continuous wavelike motion powered by a single motor. SAWbot is among the most energy-efficient swimming robots reported to date. It can swim, crawl on land, and transition between water and land while generating minimal disturbance to aquatic life.
[ Paper via IEEE Robotics and Automation ]
If you missed IROS this year, a bunch of the talks are now online, and here are a couple of good ones.
[ IROS 2026 ]
News is gathered automatically from public robotics & AI feeds on a schedule.
Related
Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva
Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots. Zlatka Stoeva is a founder and managing director of DZP Technologies, a Cambridge-based company specialising in advanced materials and novel forms of electronics. Zlat
Consumer Appetite for Personal AI Goes Mainstream
This article is brought to you by Qualcomm Technologies . For many consumers, much of the promise and appeal of AI is personal. Consumers are looking past generic tools and want to know how these technologies will help them in their daily lives. These trends coincide with the advent of new classes o
Systems Thinking Is Vital in the Age of AI
Modern engineering projects increasingly combine human judgment with machine capability. An engineer can define a problem, then ask an artificial intelligence tool to search relevant research and technical standards, generate design options, test them in simulation, and compare the results. The engi
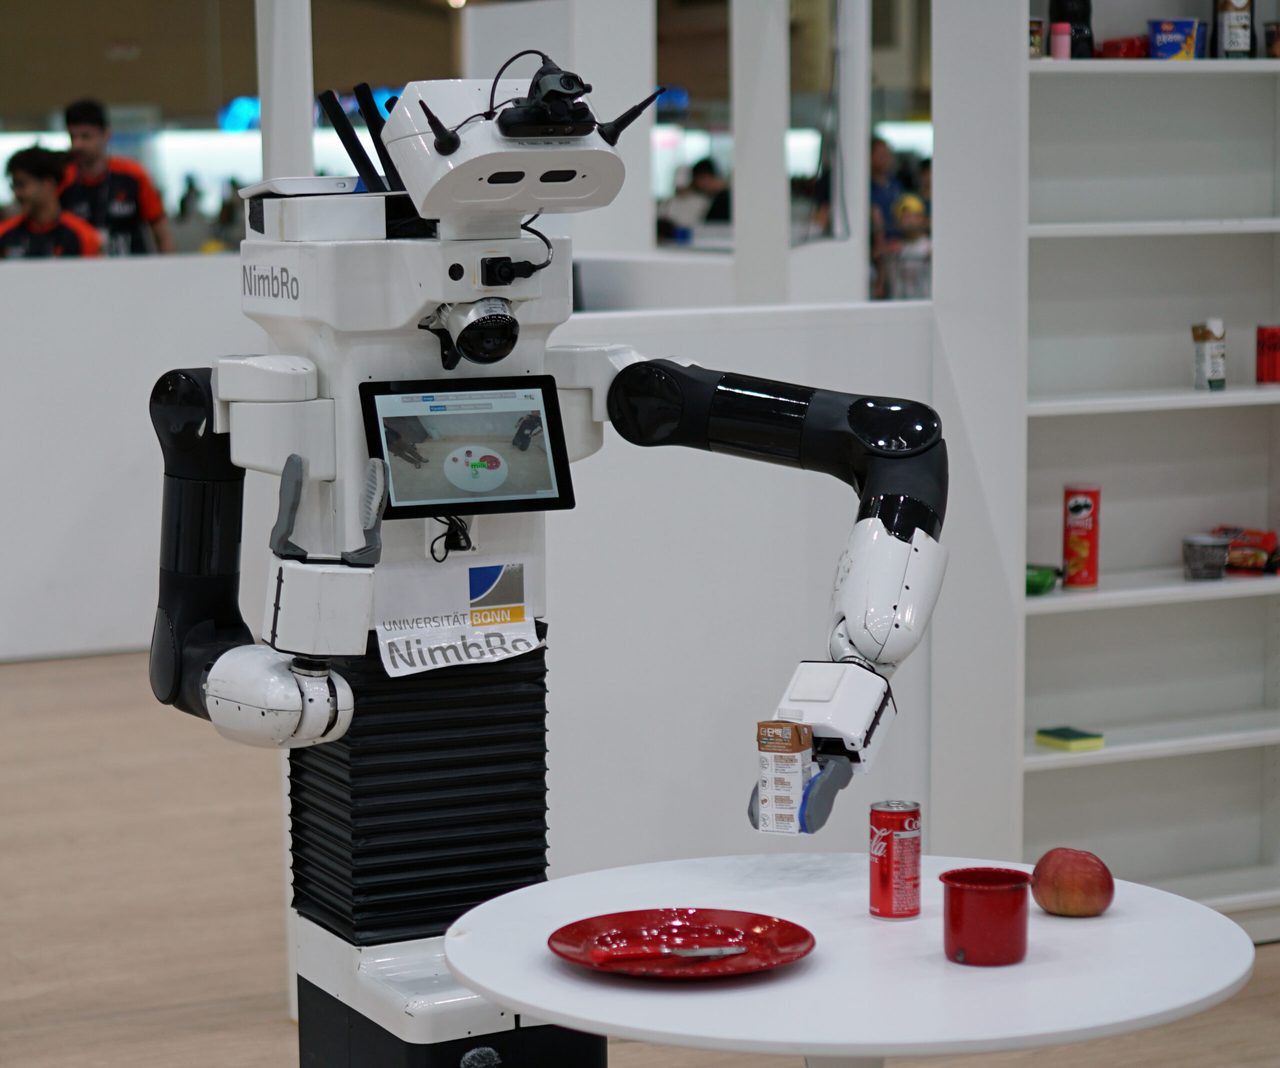
Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer
Team NimbRo’s robot in action during the RoboCup@Home competition at RoboCup 2026. Raphael leads the team. Raphael Memmesheimer has been successfully competing in the RoboCup@Home league winning the RoboCup@Home competition five times. He and his colleagues won the best paper award at RoboCup 2026 f
Your Robot’s Safety Functions Already Work. What If the Input Lies?
This article is brought to you by VicOne . A mobile robot slows for someone in a hallway. A collaborative arm eases its movement as a worker approaches. A humanoid pauses to let a person pass. Each response depends on information about the robot or its surroundings: a distance reading, a position es
I Used AI to Fake a Scientific Paper. Here’s What Happened
Science has a spam problem. And the spam filter is getting clogged up. According to all reports, academic publishing is drowning in what has come to be called AI slop: low-quality, mass-produced content generated with AI. By 2025, an estimated 57 percent of all published academic articles exhibited