Powered by muscle cells, a paper-thin robot swims through watery maze
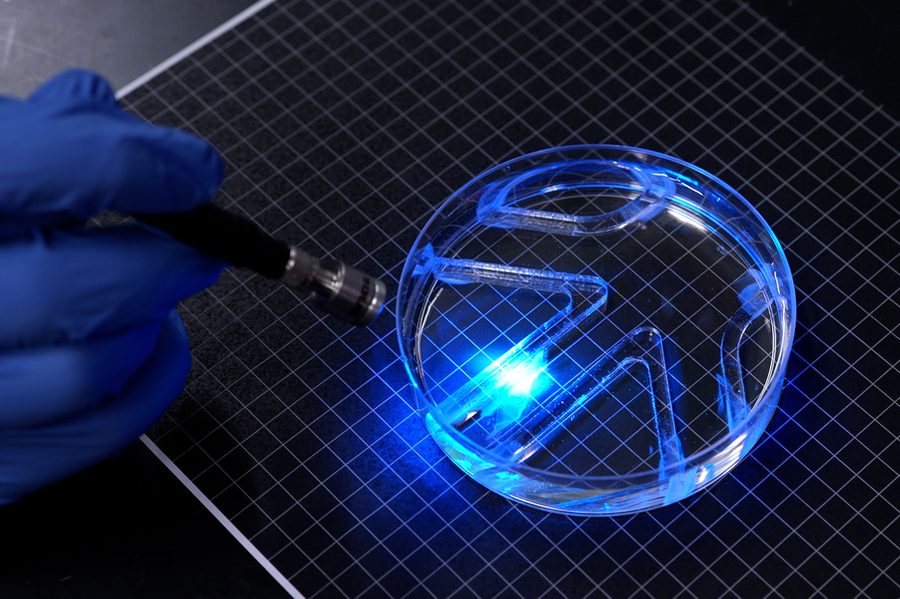
MIT engineers developed a soft robot that can flap through water in response to flashes of light. Photo credit: Melanie Gonick, MIT .
By Jennifer Chu
Swimming can take a lot of muscle. But as MIT engineers have found, even a single layer of muscle cells can power through water if designed right.
In a paper appearing today in the journal Advanced Functional Materials , the team presents a design for a thin, muscle-powered swimming robot. The “skeleton” of the aquabot is made from a film of gel that is about the length and width of a stick of gum. The two halves of the gel form the “fins” of the bot. Each fin is covered with a layer of live muscle cells that is much thinner than a single strand of hair. The cells are genetically engineered to twitch in response to light.
When the researchers shine light on one fin, the muscles on its surface twitch in response, causing the whole fin to flap with enough force to pull the robot through water. By flashing light on one fin or the other, at various intervals, they can control the swimming robot’s direction and speed.
The engineers showed that the paper-thin bot could swim and swivel through a simple watery maze. At its fastest, the robot can swim a distance of about four times its body length in one minute. That’s a snail’s pace compared to Olympic swimmers, who can cover up to 65 body lengths per minute. But the bot could hold its own against more leisurely swimmers like the cow shark, which explores the ocean at about the same rate.
In their new work, the team Raman Lab aimed to maximize muscle movements to produce more force — enough, say, to power a swimming robot. Pictured is Maheera Bawa, a graduate student at Raman Lab. Photo credit: Melanie Gonick, MIT.
“It takes a lot of force to move through water versus air,” says study author Ritu Raman, associate professor of mechanical engineering at MIT. “The robot’s quite strong, given its size.”
The new robot is the first example of a very thin, two-dimensional, muscle-powered robot capable of locomotion.
“Currently, biohybrid robots from our group and others’ are built from bulky, 3D chunks of lab-grown skeletal muscle that require millions of cells to fabricate,” says Raman, who notes that thinner, less bulky designs such as the team’s new bot could be cheaper to build and could move more efficiently. “We believe that biohybrid robots powered by living muscle could one day perform delicate jobs like exploring environments too fragile or unpredictable for conventional hardware, because living tissue is soft, responsive to its surroundings, and can heal itself.”
The study’s MIT co-authors are first author Maheera Bawa, Arielle Berman, Laura Schwendeman, Ferdows Afghah, and Seanbiron Johnson.
Maximizing movement
Last year, Raman’s group developed an iris-inspired disk of artificial muscle tissue . They stamped a disk of gel with a pattern of concentric and radial grooves, and deposited live muscle cells onto the gel’s surface. The cells formed a thin layer that grew along the grooves, and when stimulated with light, the cells moved in patterns that stretched and squeezed the disk, similar to how a human iris dilates and constricts the eye’s pupil.
That work was the first to demonstrate that muscle cells could be grown in a very thin layer, and in complex patterns that when stimulated could move in multiple, controllable directions.
“People hadn’t seen this muscle architecture engineered from scratch before,” Raman says. “And the cells were moving in multiple directions. But they only moved about 100 microns. From a robotics perspective, their movements were tiny.”
In their new work, the team aimed to maximize muscle movements to produce more force — enough, say, to power a swimming robot. The key, they found, was to optimize the skeleton on which the cells grow.
In their previous iris-inspired design, they grew muscle cells on fibrin, which is a type of ultrasoft gel that the team realized can quickly shrivel in response to the forces generated by the muscles. To better support cells and maximize their force, the researchers focused on tuning the underlying gel by changing three properties: the gel’s composition, its stiffness, and the size and shape of the grooves that are stamped into it.
“For engineering any type of tissue, it’s known that these are knobs you can tune,” Raman says. “And we wanted to optimize all these parameters to support live muscle cells.”
Tuning a skeleton
To find an optimal “skeleton” on which to grow muscle cells, the team experimented with multiple formulations of gel, of different stiffnesses, and stamped with grooves of different geometries. For instance, one groove type resembled a skinny square trough, where another was more of a long curved valley. They found that when they deposited muscles onto each type of grooved gel, cells settled into alignment in grooves that were more square than curved. More aligned cells tend to fuse into fibers that then form a stronger, more coordinated muscle tissue. Square grooves, they found, were the way to go.
Instead of using fibrin, they tried gelatin methacrylate (GelMA), a material that is often used in tissue engineering. They made different recipes of GelMA to create skeletons of different stiffnesses and observed how muscle cells grew when deposited on the gel’s surface. They found that cells grew in better alignment, and produced the most force, on stiffer gels.
The team also varied the gel thickness and found that a half-millimeter-thin film of GelMa offered good support for a single layer of muscle cells. The film was light enough that the cells were able to stick to the gel when they contracted, rather than peeling away.
Finally, the team “exercised” the muscles, using a training routine of flashing lights to strengthen the muscles.
With the pumped-up cells and the optimized gel, the team designed a thin, two-finned robot, comprising the gel, stamped on both sides with square-bottomed grooves and…
Les actualités sont collectées automatiquement depuis des flux publics robotique & IA.
Articles liés
Video Friday: When Two Robots Become One
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics. We also post a weekly calendar of upcoming robotics events for the next few months. Please send us your events for inclusion. CoRL 2026 : 9–12 November 2026, AUSTIN Humanoids 2026 :
Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova
Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms. Rika Antonova is an Associate Professor at the University of Cambridge. Her research interests include co-design, automated algorithm discovery
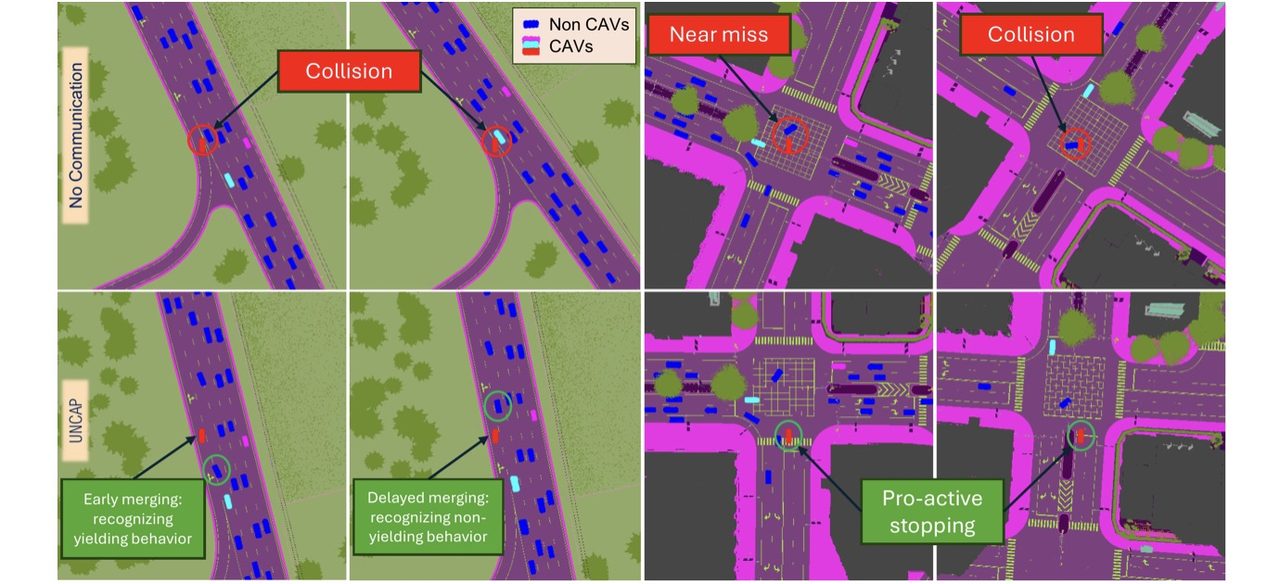
Neurosymbolic planning using natural language communication for cooperative autonomous vehicles
Imagine you are driving toward an intersection. A truck parked on the corner blocks your view of a car speeding toward the intersection from the right. You can’t see it, but the car next to you can. What if that neighboring vehicle could simply tell your car, “Vehicle merging from the right, about 1
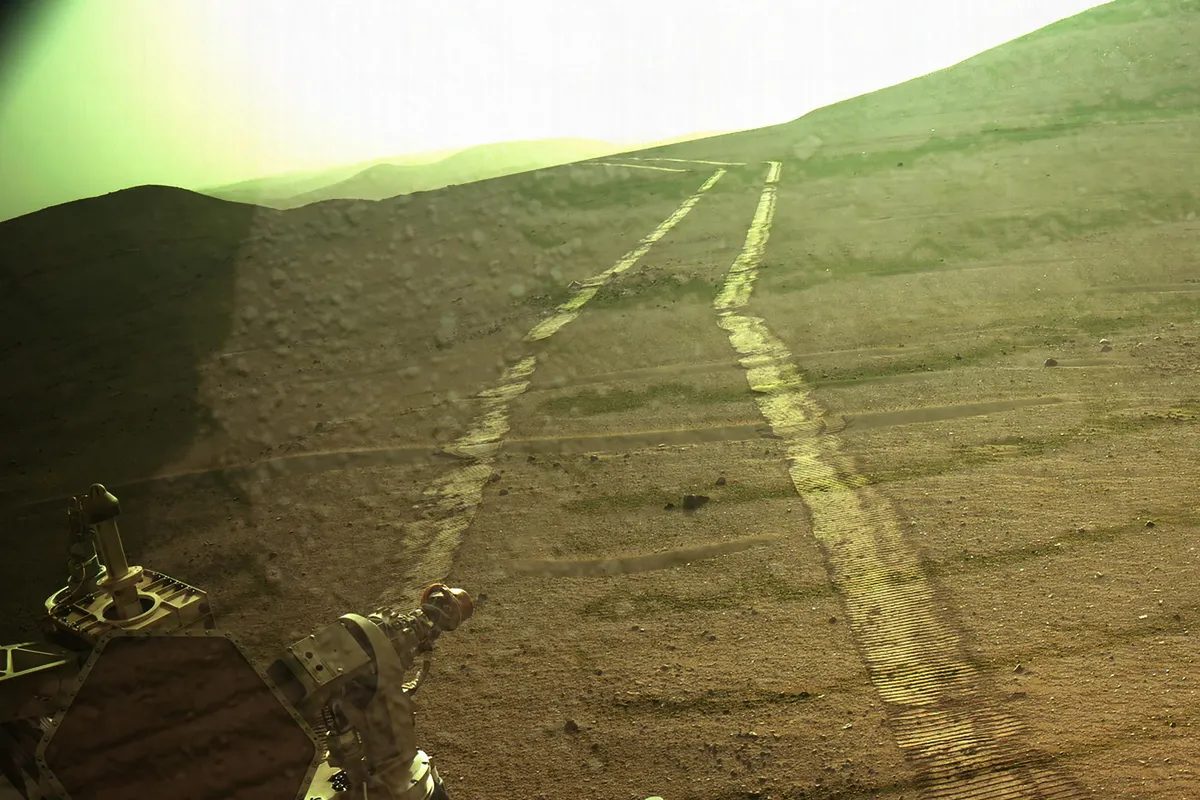
Questions et réponses : record de distance du rover Mars Perseverance
Le 11 octobre, le rover Perseverance a effectué un trajet qui a porté la distance totale parcourue sur Mars à 28,10 miles (45,22 kilomètres). Il s’agit d’un nouveau record pour les rovers martiens, rendu possible en grande partie par la capacité de Perseverance à conduire avec beaucoup plus d’autonomie que ses prédécesseurs. Au cours des cinq dernières
Les robots humanoïdes peuvent sprinter et boxer – mais le véritable test consiste à faire la lessive
Par Wai-keung Fung, Cardiff Metropolitan University Lors des récents Jeux mondiaux des robots humanoïdes 2026 à Pékin, des robots ont sprinté, boxé, joué au football et accompli des tâches inspirées des usines, des restaurants et des situations d'urgence. Le robot Tiangong Ultra a même bouclé les 100 mètres en 8,64 secondes,
Vidéo vendredi : le déclassement des robots prend une tournure amusante
Video Friday est votre sélection hebdomadaire de superbes vidéos de robotique, collectées par vos amis chez IEEE Spectrum Robotics. Nous publions également un calendrier hebdomadaire des événements robotiques à venir pour les prochains mois. Veuillez nous envoyer vos événements pour inclusion. CoRL 2026 : 9-12 novembre 2026, AUSTIN Humanoïdes 2026 :